TRANSMISSION // 2611.13779v1
What compliance changes in a passive-walker model
Source published
A mathematical study asks whether adding a spring-like joint changes which walking states are viable, or instead changes how those states are distributed. In a simplified quadratic-energy example, the projected task-state support stays the same, while sampled states shift toward lower task energy. A kernel-based measure is also lower in that example. These results suggest a way to analyze how body mechanics may shape control demands, but do not show that a physical robot walks better or needs less computation.
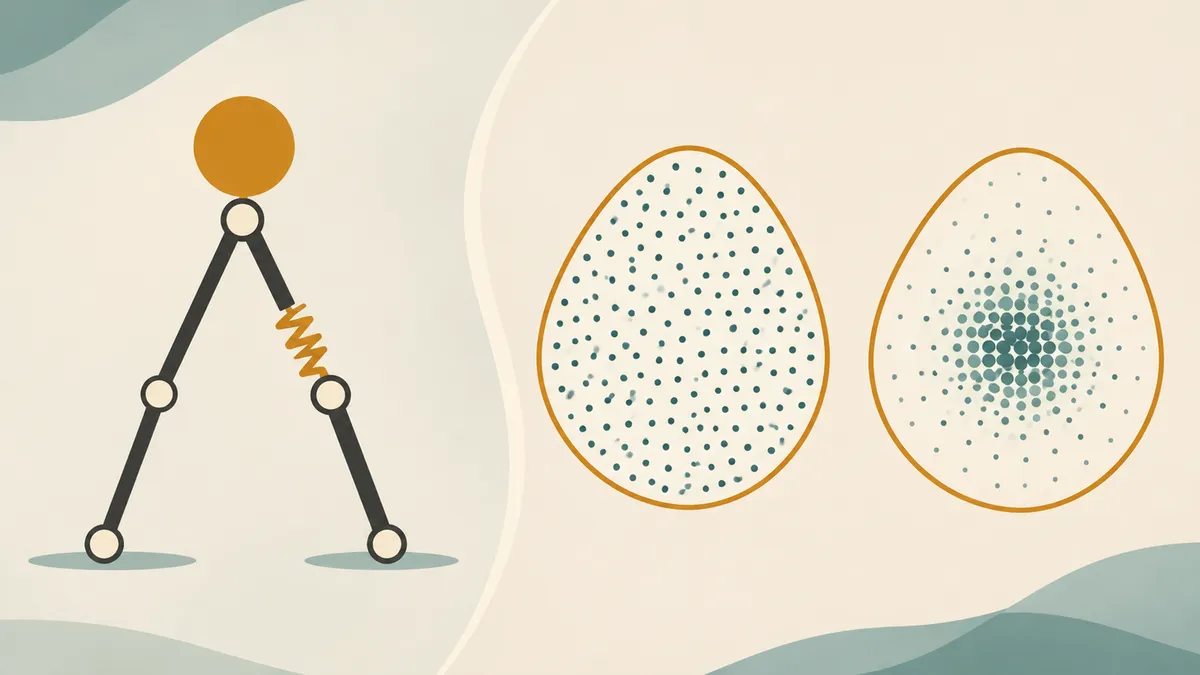
A robot’s mechanics and its controller work together, but how should that relationship be measured? This paper explores one part of the question using mathematical models of passive walking: when a model includes a compliant joint, does it change the states from which walking can continue, the distribution of those states, or both?
A passive walker is a simplified legged system whose motion can be driven largely by gravity, with little or no active control. Its movement is constrained by its energy, mechanics and foot-ground impacts. The paper by Fabio Bonsignorio and colleagues asks how compliance—a joint’s ability to flex—relates to the walker’s viable states and to measures of informational complexity.
A viable state here is not just any state a walker might reach. It belongs to a set that satisfies the model’s constraints, including energy limits and conditions for continuing after an impact. The size of that viable set describes one aspect of the system. But the set alone does not say how the dynamics distribute motion across it. Two systems could share the same projected set of task states yet populate it differently.
Models and methods
The paper discusses several passive-walking model formulations. These include the McGeer compass gait and variants that add knee–ankle compliance, foot-rocker effects or distributed leg inertia. In these models, walking combines continuous leg motion with abrupt changes at heel strike; the authors derive maps to represent those impact-related state changes.
For estimating viable phase-space volumes, the paper describes Monte Carlo methods: candidate states are sampled from a specified region and checked against energy and feasibility conditions, including post-impact conditions where relevant. It also presents a framework using reproducing kernel Hilbert spaces (RKHS). In this paper’s chosen kernel-based approach, distributions are represented in a feature space so that their statistical organization can be compared. The resulting measures depend on the chosen mathematical setup; they are not a single universal scale of complexity.
The reported comparison of rigid and compliant task-state distributions is a separate, simplified quadratic-energy example. It adds two internal variables representing the compliant joint’s position and motion. Under the example’s assumptions, including separable energy terms and an admissible zero-energy state for the compliant subsystem, the projected support of the task variables is the same as in the rigid model. In other words, adding those variables does not shrink the projected viable region in this construction.
The distribution over that shared support does change. The authors sample uniformly within the rigid model’s two-dimensional energy region, and within the compliant model’s four-dimensional energy region before projecting onto the task variables. The projected compliant samples are more concentrated around lower-energy task states. This is a consequence of the example’s sampling setup and energy model, not a report of trajectories measured from a physical robot.
The authors then calculate a finite-sample RKHS complexity measure for the two distributions. In this numerical illustration, the estimated measure is lower for the projected compliant distribution than for the rigid one. The comparison therefore concerns distributional organization, not a reduction in the projected task-state support. The paper’s broader point is that support size alone may not capture differences in how viable states are populated.
What the findings mean—and what they do not
The distinction between viable-set geometry and the distribution over that set is central to the paper. Compliance may affect one, the other, or both, depending on the model. The paper also notes that heel-strike mechanics can change the states available after impact. Neither collision energy loss nor the local contraction of an impact map alone tells us how much the full viable set changes: that depends on whether the walker can continue through the subsequent dynamics.
The numerical comparison is an illustrative model result, not evidence that compliance generally improves walking. It does not test a real robot, establish better performance, or show reduced controller runtime, memory use or energy consumption. The authors explicitly treat their RKHS quantity as an information-geometric descriptor rather than a direct measurement of controller resources; connecting it to specific control costs is future work. Results also depend on modeling assumptions, sampling choices and the selected kernel.
The source is an arXiv preprint, and the supplied material does not establish whether this version has undergone peer review. Its claims should therefore be read as a proposed framework and mathematical illustration, not as settled evidence about compliant robots. The practical question it raises is more specific than “Does softness help?”: under a given model and task, does compliance change the viable states, how those states are distributed, or both?
- passive walking
- robotics
- compliance
- morphological computation
- phase space
- kernel methods
Related reading
Automatically matched by shared topic keywords. These links do not imply that the sources agree or establish a consensus.