TRANSMISSION // 2611.13099v1
What distributed random measurements can—and cannot—reveal about quantum states
Source published
A theoretical preprint identifies which third-order properties of shared quantum states survive a particular randomized-measurement protocol. Symmetry reduces the required matrix inversions to 3 × 3 building blocks, but the retained information still grows exponentially and some quantities remain inseparable.
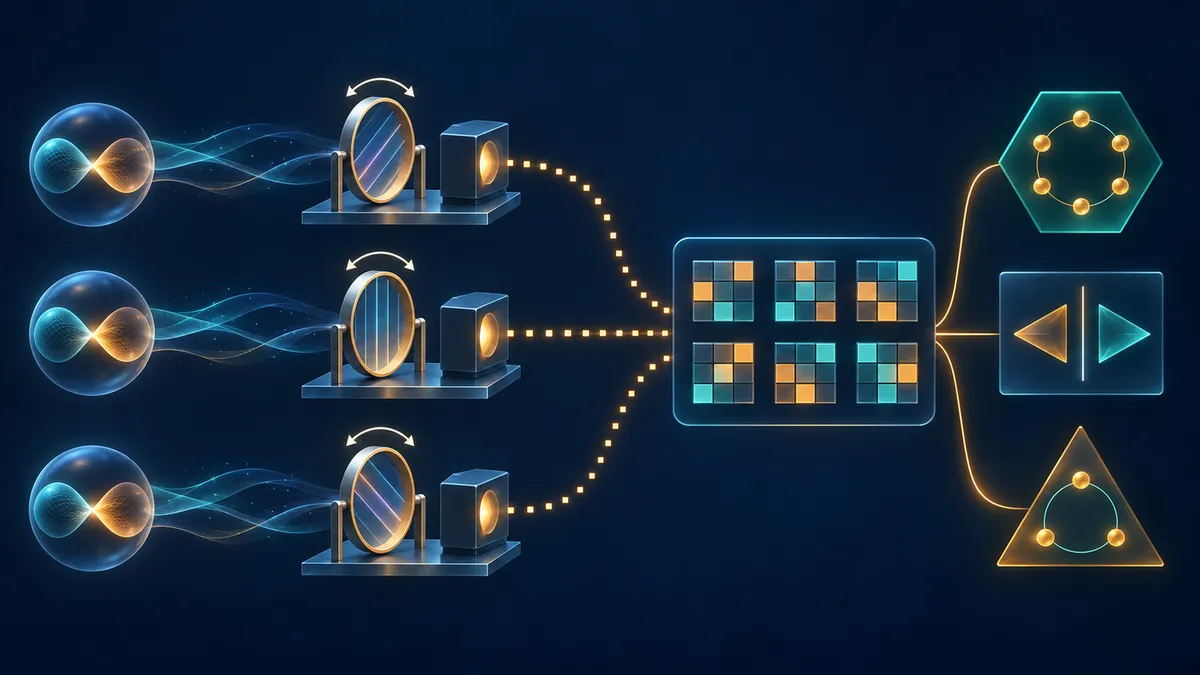
Laboratories sharing a quantum system can extract information by measuring their own subsystems and comparing classical records. A new preprint by Giovanni Scala, Corrado C. Mattiacci and Gniewomir Sarbicki establishes exactly which combinations of third-order quantum-state properties one such protocol preserves—and simplifies the mathematics needed to recover them.
Measuring without reconstructing the whole state
A quantum state's density matrix describes its measurement probabilities. Reconstructing that entire matrix is not always necessary: researchers may instead want particular nonlinear quantities, involving products of its entries. These can help characterize a state or supply inputs to entanglement tests.
The preprint studies third-order quantities, built from three factors of the density matrix. Its question is specific: what information remains when separate laboratories measure independently prepared copies using shared local settings, then retain averaged products of outcome probabilities?
The result is an analytical characterization, not an experimental demonstration. It identifies both recoverable combinations and information that this averaging procedure necessarily discards.
Three preparations, one local setting
Each laboratory applies a random quantum rotation to its subsystem and measures in a fixed basis. The laboratories choose their rotations independently, but each keeps its own rotation unchanged across three independent preparations of the shared state.
At that setting, the probability of a particular triple of outcomes is the product of three individual outcome probabilities. Averaging these products over random settings produces the data analyzed in the paper. No joint measurement coupling the three preparations is required.
The assumed randomness is mathematically precise: rotations follow the Haar distribution, the uniform distribution over unitary transformations. An exact unitary 3-design—an ensemble reproducing the relevant averages involving three unitary entries and three conjugate entries—also gives the same mean results.
Post-processing does not require storing the individual rotation matrices. It does require knowing which measurements used the same setting. That distinction does not remove the assumption that the rotations have the specified distribution.
Equality patterns expose the structure
After averaging, numerical outcome labels matter only through their equality patterns. At one laboratory, three outcomes can all differ, contain exactly one equal pair, or all coincide. There are three possible positions for the equal pair, giving five labeled patterns.
The researchers then exploit another symmetry: relabeling the three complete preparations simultaneously at every laboratory cannot change the probability product. Grouping patterns related by this relabeling removes duplicate coordinates without losing additional information.
The quantities reconstructed are local-unitary invariants: combinations of the density matrix unchanged by independent changes of basis at each laboratory. The derivation expresses them through permutations of three copies, then separates the reconstruction equations into independent mathematical sectors.
Within those sectors, the only nontrivial inversions needed are copies of a known 3 × 3 matrix, supplemented by scalar divisions. Larger blocks are assembled from tensor products of these local building blocks rather than inverted as unrestricted dense matrices.
A definite information limit
Simpler reconstruction does not mean complete access to third-order properties. The averaging assigns identical coefficients to two opposite cyclic permutations of the three copies at each laboratory. Consequently, their contributions appear only as sums; their differences cannot be recovered from these data.
For two laboratories, an important example is the sum of the global third moment, Tr(ρ³), and the third moment after partial transposition of one subsystem. Partial transposition swaps matrix indices belonging to that subsystem; it is a mathematical operation used in entanglement analysis, not a physical rotation.
The protocol cannot separate those two moments. The paper contrasts this restriction with approaches that retain individual random settings and can estimate partial-transpose moments separately. Its information limit therefore concerns these particular averaged correlators, not all distributed randomized measurements.
What the simplification does not establish
The retained coordinate count still grows exponentially with the number of laboratories: the paper gives 3 coordinates for one party, 10 for two and 37 for three. Avoiding large matrix inversions does not eliminate that growth.
Nor does the theorem establish favorable measurement counts, precision or numerical conditioning. Efficient statistical estimators remain an open task. Experimental frequencies must also be divided by the appropriate outcome and symmetry multiplicities before reconstruction.
There is a low-dimensional caveat: three distinct outcomes are impossible for a two-level subsystem, and the displayed local averaging formulas have a singularity there. The source notes this issue, so the five-pattern inversion should not be treated as an unqualified recipe for qubits.
The contribution is thus precise but bounded: symmetry provides an exact reconstruction framework for the information these averages retain, while also showing why some distinctions remain inaccessible.
- quantum information
- randomized measurements
- distributed quantum systems
- local-unitary invariants
- third-order moments
- partial transposition
- quantum-state characterization
Related reading
Automatically matched by shared topic keywords. These links do not imply that the sources agree or establish a consensus.
Let the measurements choose: adapting quantum entropy estimates
Source published
Shared keywords: randomized measurements
A broader proof links quantum information to horizon geometry
Source published
Shared keywords: quantum information
A quieter route to tunable light–matter interactions
Source published
Shared keywords: quantum information
When a quantum state leaves its starting point before perfect transfer
Source published
Shared keywords: quantum information
Why finite quantum circuits cannot reproduce the quantum switch
Source published
Shared keywords: quantum information