TRANSMISSION // 2611.07699v1
For electric robotaxis, the best charging stop may come before the battery runs low
Source published
A preprint models how electric robotaxi fleets should coordinate charging and empty journeys. In a New York-calibrated numerical exercise, battery-aware control raises modeled peak-hour profit by 10.9% over an approximate battery-oblivious benchmark. Simple threshold rules recover most of the gap, but the results are not evidence from an operating fleet.
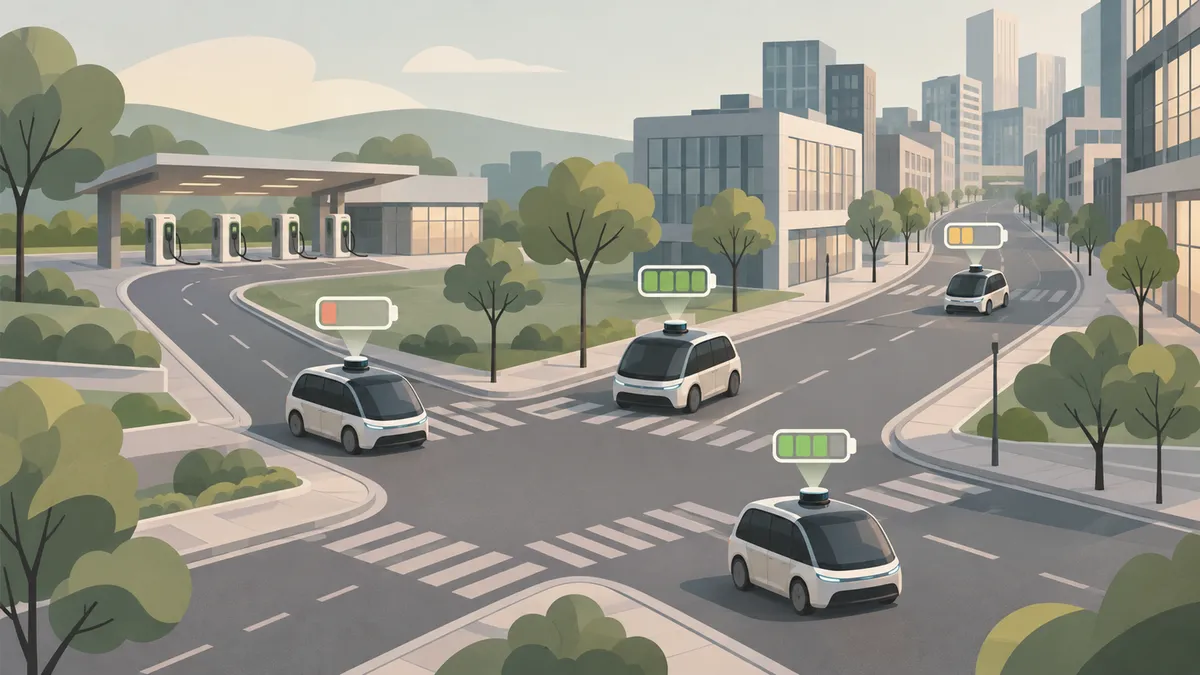
An electric robotaxi near its charging depot faces a deceptively difficult choice: take another fare, move toward busier streets, or recharge while the depot is convenient. New research argues that waiting until the battery reaches its minimum operating level can waste valuable fleet time—and that a vehicle’s remaining charge should help determine where it goes next.
Two robotaxis on the same street are not interchangeable if one has a nearly depleted battery and the other has hours of service left. Sending both toward a busy district may leave the first making an expensive detour to recharge just as the second starts earning fares.
That is the central economic mechanism in Stay, Reposition, or Recharge: Battery-Aware Operation of Robotaxi Fleets, by Philipp Afèche, Saif Benjaafar and Jiayu (Kamessi) Zhao. Their November 5, 2026 arXiv preprint develops mathematical operating rules and evaluates them in a numerical network calibrated to New York trip records. Its profit gains are model outputs, not measured improvements from a robotaxi deployment. The supplied materials do not establish peer-reviewed publication.
A battery has a location-dependent value
The authors build a continuous-time, deterministic fluid model: instead of tracking individual cars and random requests, they optimize steady-state vehicle flows across locations and discrete battery levels. A linear program chooses passenger service, empty repositioning, idling, depot returns and relaunches, subject to demand, flow conservation and available vehicle time.
The objective is revenue net of repositioning costs, with service revenue defined net of operating costs. Charging consumes vehicle time, creating an opportunity cost, but the base formulation does not explicitly charge for electricity. This is an operating objective, not a complete accounting of business profitability. Prices and demand are fixed rather than responding to the policy.
The model yields location-specific battery thresholds: depot returns are excluded above a threshold, while empty repositioning is excluded below it. Earlier charging can be worthwhile near a convenient depot, particularly where service opportunities are weak. Returning at higher charge requires more frequent depot visits, whose travel and fixed charging-setup time reduce effective fleet capacity. The benefit is avoiding a later return from a location where reaching the depot could cost more or take longer; remaining charge is not discarded.
A second result concerns “battery sensitivity”: the extra operational value of another unit of charge at a destination. Under the theorem’s ordering conditions, low-charge vehicles should not be repositioned to the more battery-sensitive destination, nor high-charge vehicles to the less sensitive one. Otherwise comparable locations with worse depot access are more battery-sensitive, because extra charge postpones an inconvenient charging trip. This is not simply a rule to send every charged car to the busiest neighborhood.
What the New York exercise finds
The calibration uses 2025 New York City Taxi and Limousine Commission high-volume for-hire trip records, including Uber and Lyft journeys. The researchers aggregate Manhattan into 64 zones and add an external depot in Queens. Observed trip counts, destination shares and average fares supply demand and revenue inputs.
They assume 7,000 vehicles operating between 20% and 80% physical battery charge, divided into 24 steps. Each service or repositioning task consumes one step; idling consumes a step over 45 minutes. Eligible service and repositioning arcs are restricted to centroid distances of at most 7.5 miles. Every depot visit takes one hour regardless of arrival charge, including charging and operational overhead. Empty movement costs $0.70 per mile.
For Monday peak conditions, 3–9 p.m., fully battery-aware control raises modeled profit by 10.9%, approximately $13,400 per hour. Under separately calibrated Monday off-peak conditions, midnight–6 a.m., the increase is 33.9%, approximately $6,700 per hour. The larger off-peak percentage therefore represents a smaller dollar gain.
These comparisons use an approximate battery-oblivious benchmark, not its proven global optimum. The benchmark disallows early depot returns and makes repositioning proportions independent of charge. Solving that constrained optimization exactly is computationally difficult; the authors fix proportions derived from the battery-aware solution. A coordinate-wise grid search improves the proxy by just 0.9%, but this local check does not establish global optimality.
Simplified charging and repositioning thresholds together recover 82.9% of the modeled gap over that proxy. Repositioning rules alone recover 79.1%; charging rules alone recover 28.4%. These heuristics still draw location classifications and battery-value information from optimization, rather than dispensing with it altogether.
Useful guidance, not a deployment forecast
The analytical claim of an “unbounded” gain is a worst-case profit ratio in constructed two-location examples: the oblivious policy can earn zero while the aware policy remains profitable. It does not predict unlimited profits or a typical real-world gain.
Practical constraints also matter. In the calibrated capacity experiment, early charging disappears when simultaneous charging capacity falls below roughly 13% of fleet size. Scarce charging slots can eliminate the room for proactive returns.
The demand data contain completed trips, not unfulfilled requests. The main comparison treats peak and off-peak as separate stationary systems, omits stochastic depot queues, and simplifies energy consumption and charging. Extensions explore richer settings, but nonlinear charging can break simple thresholds; the time-varying return-threshold result requires charging duration independent of arrival charge.
The defensible takeaway is narrower than a profit forecast: remaining battery charge and depot geography should be considered jointly. A charging decision changes not only when a vehicle earns again, but where its remaining operating time is most valuable.
- robotaxis
- electric vehicles
- fleet management
- battery-aware control
- vehicle repositioning
- charging depots
- operations research
- New York City