TRANSMISSION // 2611.03717v1
PhysFTM reconstructs physical fields from sparse sensors and missing frames
Source published
A preprint introduces PhysFTM, a method combining compact continuous field representations with equation-based constraints. The authors report lower reconstruction errors in most tested comparisons, while documenting limits involving missing intervals, physical-model availability and uncertainty.
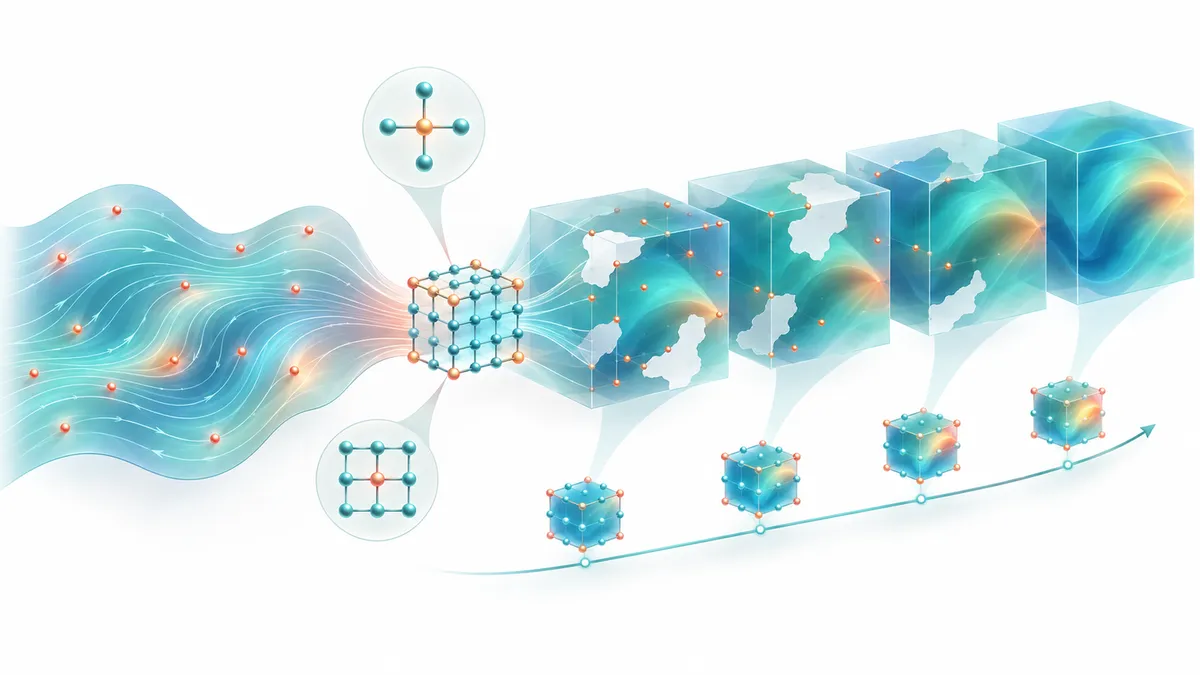
Sparse sensors can leave most of a changing physical field unobserved, and missing recordings add another layer of ambiguity. Zhengyang Liu and colleagues propose PhysFTM to reconstruct those gaps using a compact spatial representation, learned temporal corrections and, where enabled, constraints from governing equations.
A model can match every available sensor reading and still reconstruct the surrounding field incorrectly. That ambiguity motivates PhysFTM, a method described by Zhengyang Liu and colleagues in a preprint posted on October 31, 2026. The authors combine a compact mathematical representation of spatial fields with temporal modeling and equation-based constraints. Their experiments report improvements across several reconstruction benchmarks, but not a universal win or a guarantee of recovering the true field.
A compact representation with physical guidance
PhysFTM separates spatial structure from its evolution over time. Its spatial decoder uses a functional Tucker representation: coordinate-dependent building blocks are combined through a smaller array of coefficients called a core tensor. Changing the core changes the reconstructed field without requiring a new spatial representation for every frame.
The spatial building blocks belong to reproducing kernel Hilbert spaces, or RKHSs. In this implementation, kernel functions define those building blocks, while a regularization penalty controls their complexity. The resulting decoder can evaluate fields at sensor locations, unobserved locations and coordinates between grid points.
Where an equation constraint is enabled, the method also penalizes departures from that equation at locations away from sensors. These departures, called residuals, are calculated using finite differences between neighboring field evaluations. They supply constraints where direct measurements are absent; they do not constitute additional observations of the true field. Training alternates between solving for the cores with fixed spatial factors and updating those factors through gradient-based optimization.
Filling gaps in time
After training the spatial decoder, PhysFTM freezes it and infers cores for a new sequence from its sparse measurements. Under severe sparsity, the authors found that directly regularizing cores could produce near-zero coefficients and low-energy reconstructions. Their approach instead solves for corrections around a mean core trajectory calculated from training data.
For times between observed frames, the method starts with cubic Hermite interpolation through the inferred support-frame cores. A learned recurrent model adds a correction in core space. A gate makes that correction vanish at interval endpoints, preserving the inferred endpoint cores. These are in-range reconstructions, not demonstrations of forecasting beyond the observed time span.
What the experiments measured
The authors tested three simulated systems—two-dimensional Allen–Cahn dynamics, two-dimensional Navier–Stokes flow and three-dimensional heat diffusion—and three-dimensional horizontal ocean currents from Copernicus reanalysis. The ocean benchmark is therefore a reconstruction of a gridded reanalysis product, not a deployment using physical sensor instruments.
Training used observations at 15% of spatial locations, with evaluations at 1%, 3% and 15%. Sensors stayed fixed within each trajectory. One temporal protocol randomly withheld approximately half the internal frames; another withheld a contiguous internal block containing 20% of frames. Both retained the endpoints.
Errors were reported separately for sensor and off-sensor locations, and for observed and missing frames. At 3% spatial coverage, PhysFTM achieved the lowest root mean squared error in most comparisons. For off-sensor locations in randomly missing Allen–Cahn frames, its RMSE was 0.09988, compared with 0.32038 for LRTFR. On Navier–Stokes under the same protocol, it scored 0.06498, compared with 0.10441 for RecFNO.
Longer uninterrupted gaps exposed limitations. For ocean off-sensor locations during the withheld interval, PhysFTM scored 0.18565, slightly worse than LRTFR’s 0.18377. The heat and ocean interval evaluations also reused temporal models trained with randomly missing frames.
Physical diagnostics gave a mixed picture. At 3% coverage, PhysFTM had the lowest Navier–Stokes missing-frame vorticity and energy-spectrum errors under both protocols, but PINNs had lower divergence residuals. Low equation residuals alone were not sufficient: one Allen–Cahn ablation had a very small residual yet poor reconstruction accuracy.
What the findings do not establish
The ocean configuration used no governing-equation loss. The temporal head was trained on core reconstruction targets, with temporal equation losses disabled. Consequently, the results should not all be attributed to direct physics enforcement.
The comparisons also used different conditioning and fitting arrangements. Notably, the SIREN-MLP and PINNs controls received no test-sequence sensor conditioning or adaptation. PhysFTM used dense training fields for spatial checkpoint selection and dense validation fields to select its temporal checkpoint, although spatial reconstruction gradients used sparse observations and the stated regularizers.
The paper’s theoretical analysis concerns an idealized spatial estimator with independent sampling and smoothness assumptions, rather than certifying the full experimental pipeline. The authors also acknowledge reliance on suitable equations where physics constraints are used, restriction to fixed sensors, and the absence of reconstruction uncertainty estimates. Their evidence supports improved reconstruction in the tested settings, not uniquely determined recovery from sparse data.
- PhysFTM
- sparse sensors
- spatiotemporal reconstruction
- functional Tucker decomposition
- reproducing kernel Hilbert spaces
- physics-informed learning
- missing frames