TRANSMISSION // 2611.03675v1
Teaching AI latent spaces a preferred direction of change
Source published
A preprint introduces learned Randers geometry to make movement through image representations direction-dependent. Tests on synthetic head images and plant-growth photographs show more consistently increasing trajectories than symmetric geometric baselines, under strong assumptions about how progression is ordered.
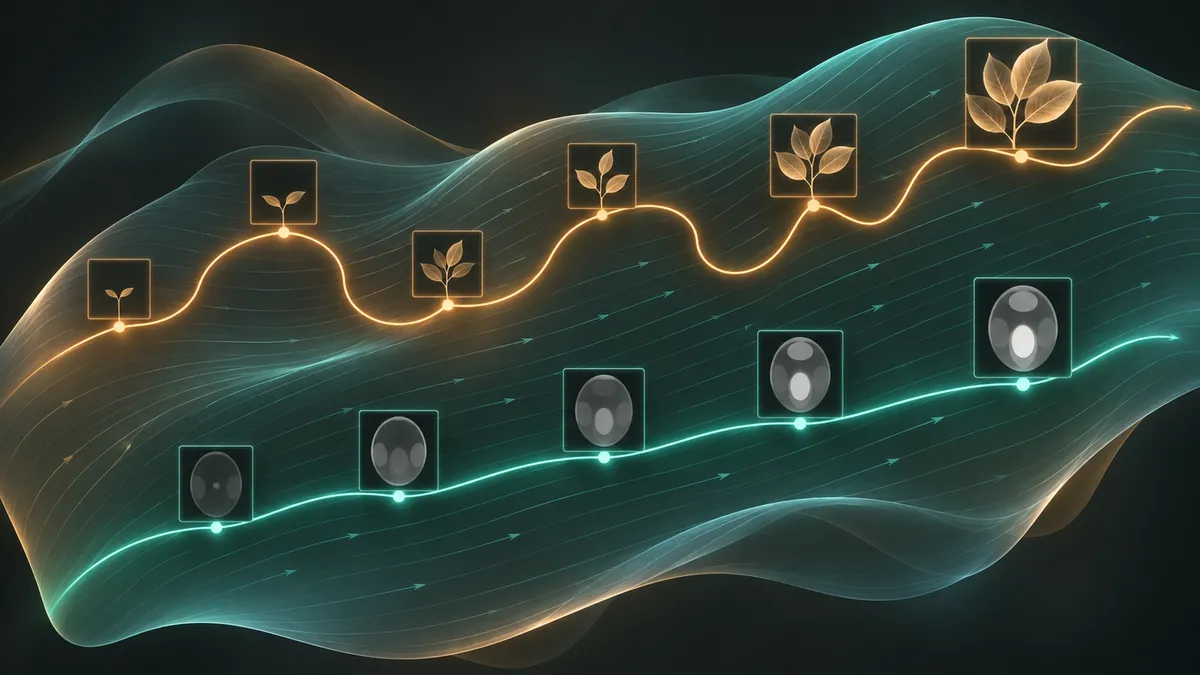
Connecting two known images is different from generating a plausible continuation from just one. Théau Blanchard and Stéphanie Allassonnière investigate that distinction by teaching an image model’s latent space which direction represents progression. Their results demonstrate the approach in controlled settings, not clinical forecasting.
Image-generating neural networks can compress pictures into numerical representations called latent codes. Moving between these codes and decoding the intermediate positions produces a sequence of images. But a route that connects two observations does not necessarily provide a useful rule for continuing beyond one observation.
In the preprint Learning Directional Randers Geometry for Latent-Space Exploration, Théau Blanchard and Stéphanie Allassonnière propose giving such movements different costs depending on their direction. Their experiments ask whether this asymmetric geometry can generate sequences that follow a known, consistently increasing image property.
Curvature does not specify progression
Ordinary Euclidean geometry treats travel in opposite directions equally. Riemannian geometry can change distances according to location and account for curvature, but its local movement costs remain symmetric. Neither symmetry nor curvature alone identifies which way a sequence should develop.
The authors instead use a Randers metric, a particular form of Finsler geometry. It adds a directional term to a Riemannian movement cost. At a given position, moving with the learned preferred direction becomes cheaper than moving against it. The directional contribution is bounded so that nonzero movements retain positive costs.
This is a preference encoded in geometry, rather than a hard prohibition on reverse movement. The experiments therefore measure how consistently generated sequences follow the desired ordering.
Learning from snapshots
The method starts with images, their latent representations and a scalar score describing the progression of interest. It assumes that this score changes monotonically along an individual sequence and can reliably order observations across the dataset.
That second requirement is substantial. In a clinical application, the authors explain, it would mean being able to compare progression between different patients using their scores. The framework does not remove the need for progression information; it uses ordered snapshots instead of requiring repeated observations of each individual.
Two small neural networks learn the directional addition after the image representation is available. One learns to distinguish locally earlier from later examples among nearby latent points. The other estimates the strength of that local ordering, reducing the directional contribution where the separation is unreliable.
For extrapolation, the procedure also samples movement directions around the learned preferred direction, then advances trajectories using the asymmetric geometry. Thus, the reported comparison involves direction-informed sampling as well as direction-dependent movement costs. The symmetric baselines instead sample directions without that learned forward preference.
Tests on simulated heads and growing plants
The researchers trained variational autoencoders and evaluated five base geometries, both with and without the directional extension. Their synthetic Shepp–Logan dataset contained 1,000 training images and 500 test images. A changing ellipse area served as a proxy for tumour size, rather than representing measurements from actual tumours.
The second dataset, KOMATSUNA, contained plant-growth photographs, with 720 training images and 180 test images. Leaf area supplied the progression score. The controlled evaluation assumed continuous, totally ordered progression factors and initially noise-free labels.
Generated trajectories were decoded into images, from which the progression score was recovered. Kendall’s rank correlation measured whether that score increased with trajectory step. Relative variation measured the percentage change from the initial score, helping distinguish substantial progression from an almost stationary sequence.
With a Euclidean base geometry, the reported average extrapolation correlation rose from 0.02 to 1.0 on the synthetic heads and from −0.05 to 1.0 on the plants when the directional framework was added. Average relative variation reached 85.59% and 138.56%, respectively. These percentages describe changes in generated image properties, not validated biological growth rates.
Stronger extrapolation, qualified gains
Interpolation between known endpoints did not improve consistently. The paper proves that when the directional term is the differential of a smooth potential, shortest paths between fixed endpoints remain unchanged apart from their parameterization, although their lengths can differ.
Performance also depended on the underlying geometry. The directional PBCentroids variant achieved substantially weaker extrapolation correlations than most other directional variants. A separate Wasserstein gradient-flow baseline already produced high correlations: 0.97 on the synthetic heads and 0.87 on the plants.
Additional experiments found tolerance to small label perturbations, but increasing noise could sharply reduce the amount of progression even while rank correlation stayed high. Sampling concentration and movement speed also affected exploration.
The authors identify scaling to larger datasets and relaxing the total-ordering assumption as future work. The preprint supports directional geometry as a useful modelling ingredient in these controlled experiments. It does not establish that generated trajectories predict an individual patient’s future.
- latent space
- Randers geometry
- Finsler geometry
- directional metric learning
- variational autoencoder
- image extrapolation
- monotonic progression